From language to robot actions
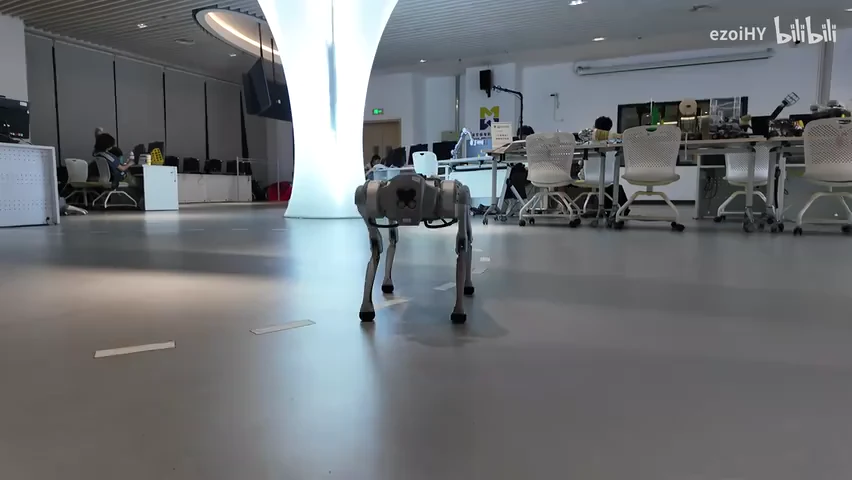
This engineering project uses a Unitree Go1 quadruped to explore how natural-language instructions can be translated into locomotion and interaction.
I deployed Qwen models locally through Ollama and built an API pipeline connecting model outputs to the robot’s motion-control interface.
Implementation
- Deployed Qwen models locally.
- Connected natural-language instructions to robot actions.
- Built an API pipeline from model outputs to the motion-control interface.
This project is part of my exploration of language models in physical robot systems. It also prompted me to consider how perception, interaction, and motion execution work together within a single system.