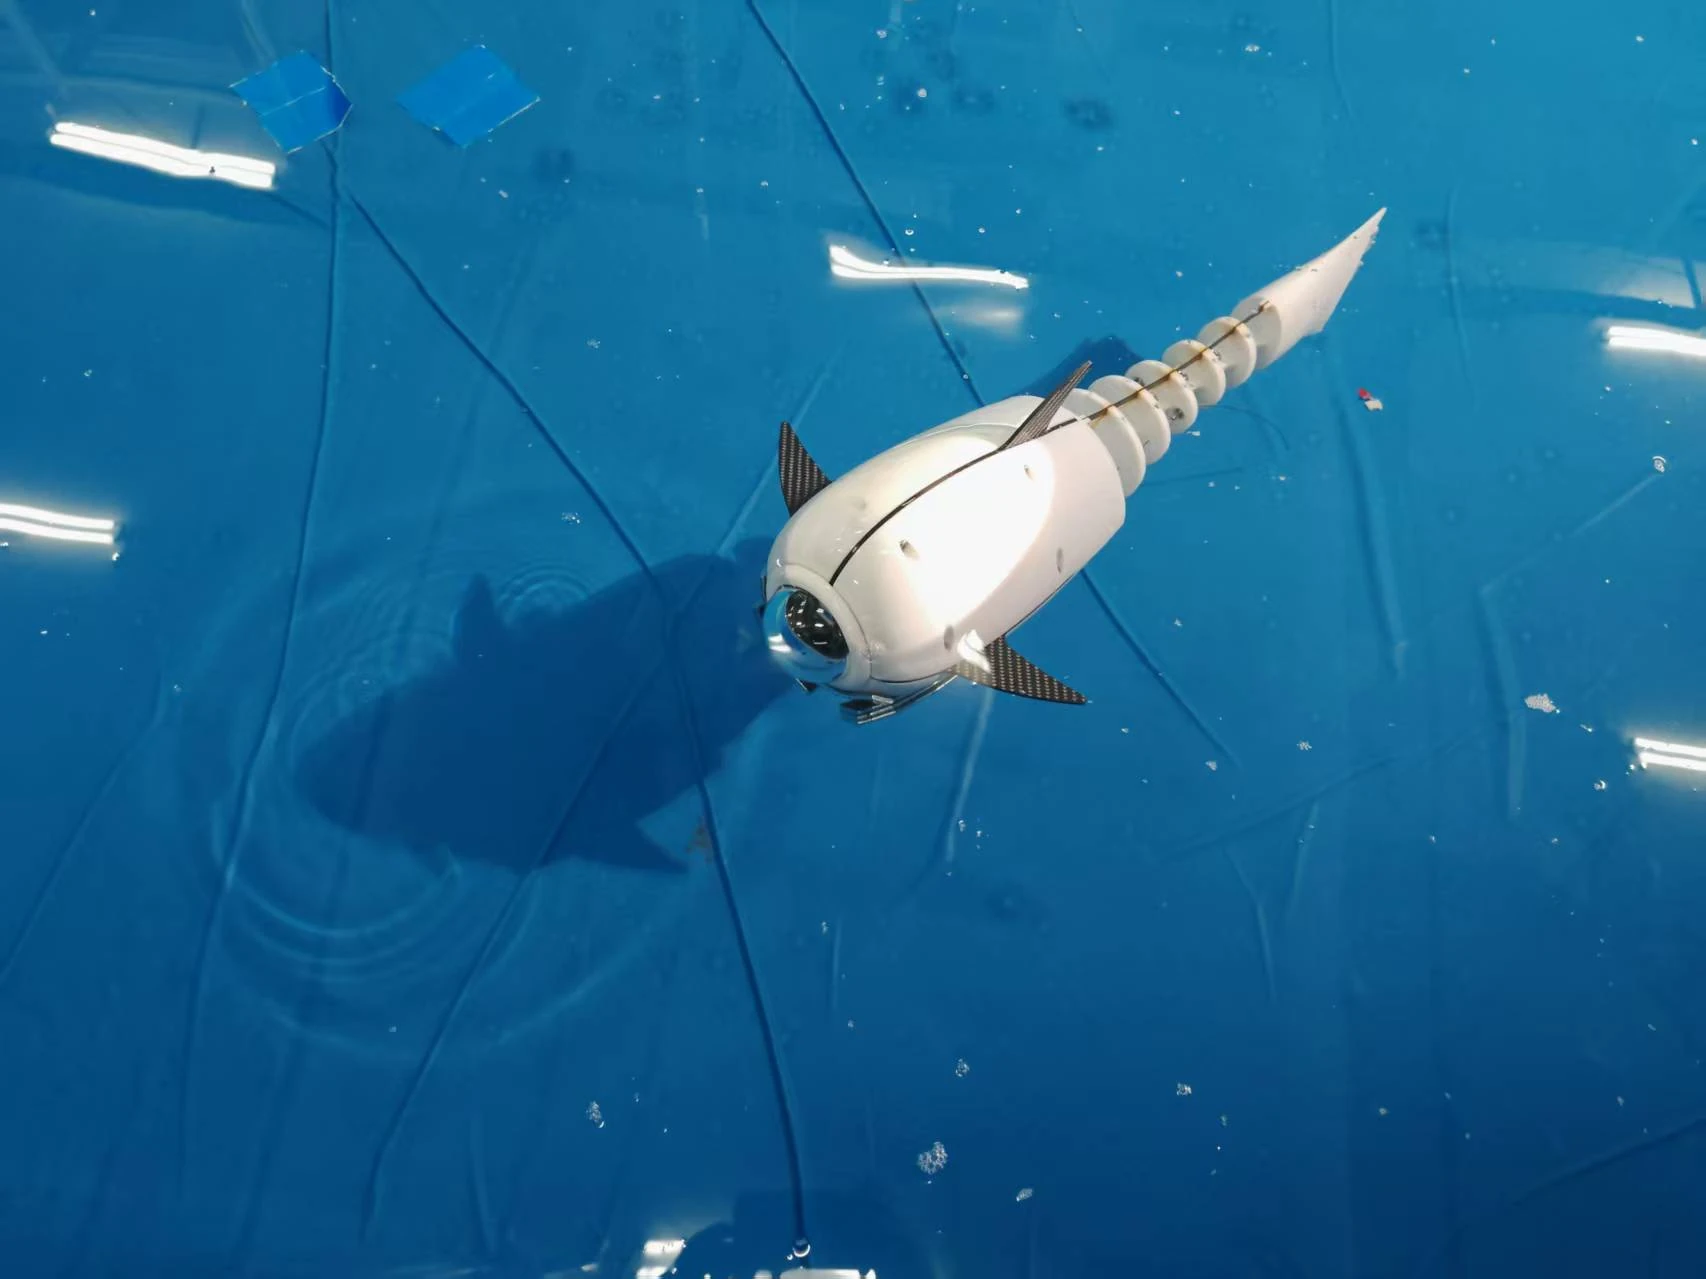
Underwater perception and collaboration
I am participating in a national-level student innovation project on underwater human–robot collaboration. The project uses a vision-guided biomimetic robotic fish to investigate scene recognition and diver tracking.
My contributions
- Responsible for visual recognition and diver tracking.
- Contributed to the algorithm architecture.
- Developed a scene-recognition module based on YOLOv8.
- Assisted with improvements to the fish’s mechanical structure.
This work has given me experience with visual algorithms within a complete robot system and helped me understand the connections between perception, algorithm architecture, and mechanical design.