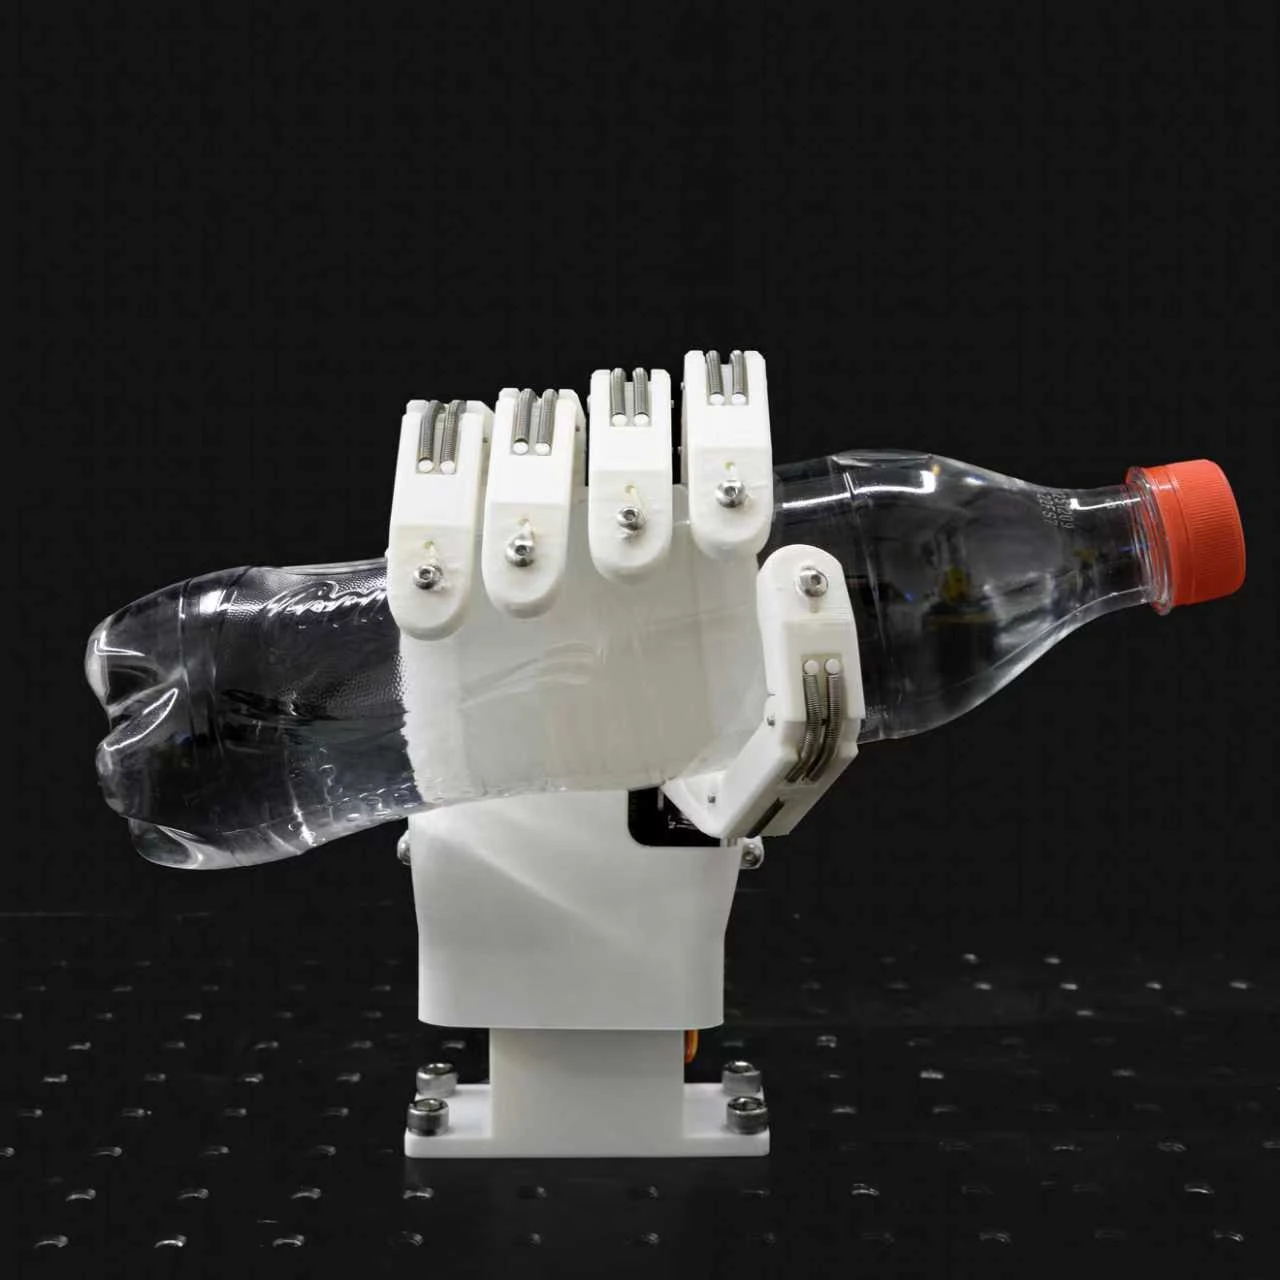
Mechanism design for adaptive grasping
This project focuses on a pulley-free, tendon-driven underactuated prosthetic hand. A single actuator and a compact underactuated mechanism allow the fingers to move adaptively and distribute grasping forces during grasping.
My aim is to use mechanism and transmission design to achieve reliable grasping with fewer actuators and lower system complexity.
Completed work
- Designed a prosthetic hand with a mass of 304 g.
- Implemented adaptive finger motion and grasping-force distribution through tendon transmission and an underactuated mechanism.
- Verified stable grasping.
- Verified operation in wet and underwater conditions.
This work has informed my continuing interest in the relationship between mechanism design, force transmission, and operating conditions.